Perception and positioning
An Arducam autofocus camera supplied images for object and colour detection. An ultrasonic sensor added distance information, while the M9N GPS provided the position reference for surveying and flight navigation.
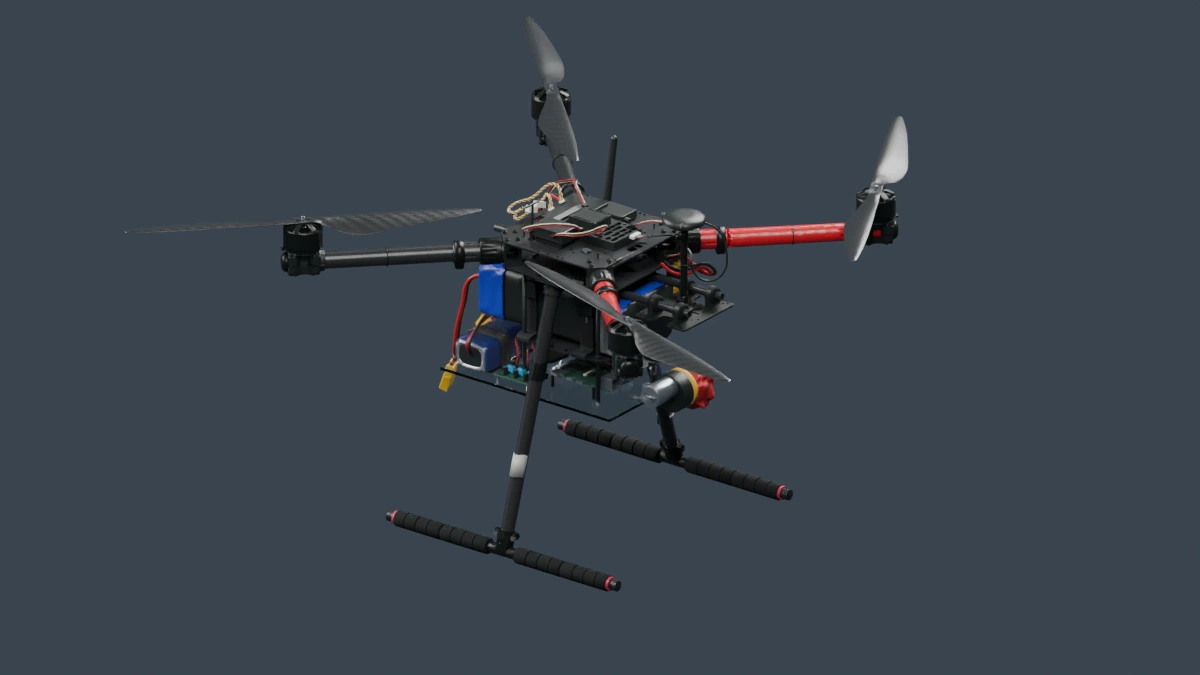
Rotatable view of the supplied UAV 1.0 assembly. The robotic arm and gripper are not included in this model.
Use your mouse or trackpad: drag to rotate, scroll to zoom.Drag to rotate. Pinch to zoom. With the model focused, use arrow keys to rotate, + or - to zoom, Home to reset, and Escape to leave the model.
Design estimate
Design target
Design target
6S 25C LiPo
4 × carbon fibre
Arducam autofocus
An Arducam autofocus camera supplied images for object and colour detection. An ultrasonic sensor added distance information, while the M9N GPS provided the position reference for surveying and flight navigation.
Four MN4014 motors and 17-inch propellers provided lift on a carbon-fibre X650 frame. The Pixhawk 6X ran PX4 flight control, adjusting motor outputs to manage the aircraft’s position and attitude.
A 6S pack supplied propulsion, with a separate battery for the payload. Water-activated flotation devices supported recovery after a water landing, and protective enclosures were designed for the onboard electronics.
Telemetry connected the aircraft to the ground station for status and mission control. A separate handheld radio provided manual takeover, and the video link let the team monitor the onboard computer during troubleshooting.
A Raspberry Pi processed images with OpenCV and TensorFlow. The navigation design combined survey paths with visual landing markers, connecting perception and positioning to the Pixhawk’s flight-control functions.
A five-axis robotic arm carried a gripper adapted for small tins. The team revised the arm’s motion calculations to fit the X650 frame, with a servo controller coordinating the joints.
Stereo vision, onboard GPU computing, LiDAR and a winch shaped the aircraft’s next role at SUAS 2025.