Perception and positioning
A ZED 2i stereo camera supplied object detections and depth. The Hemisphere GNSS receiver provided position and heading, while a hydrophone listened for acoustic signals beneath the surface.
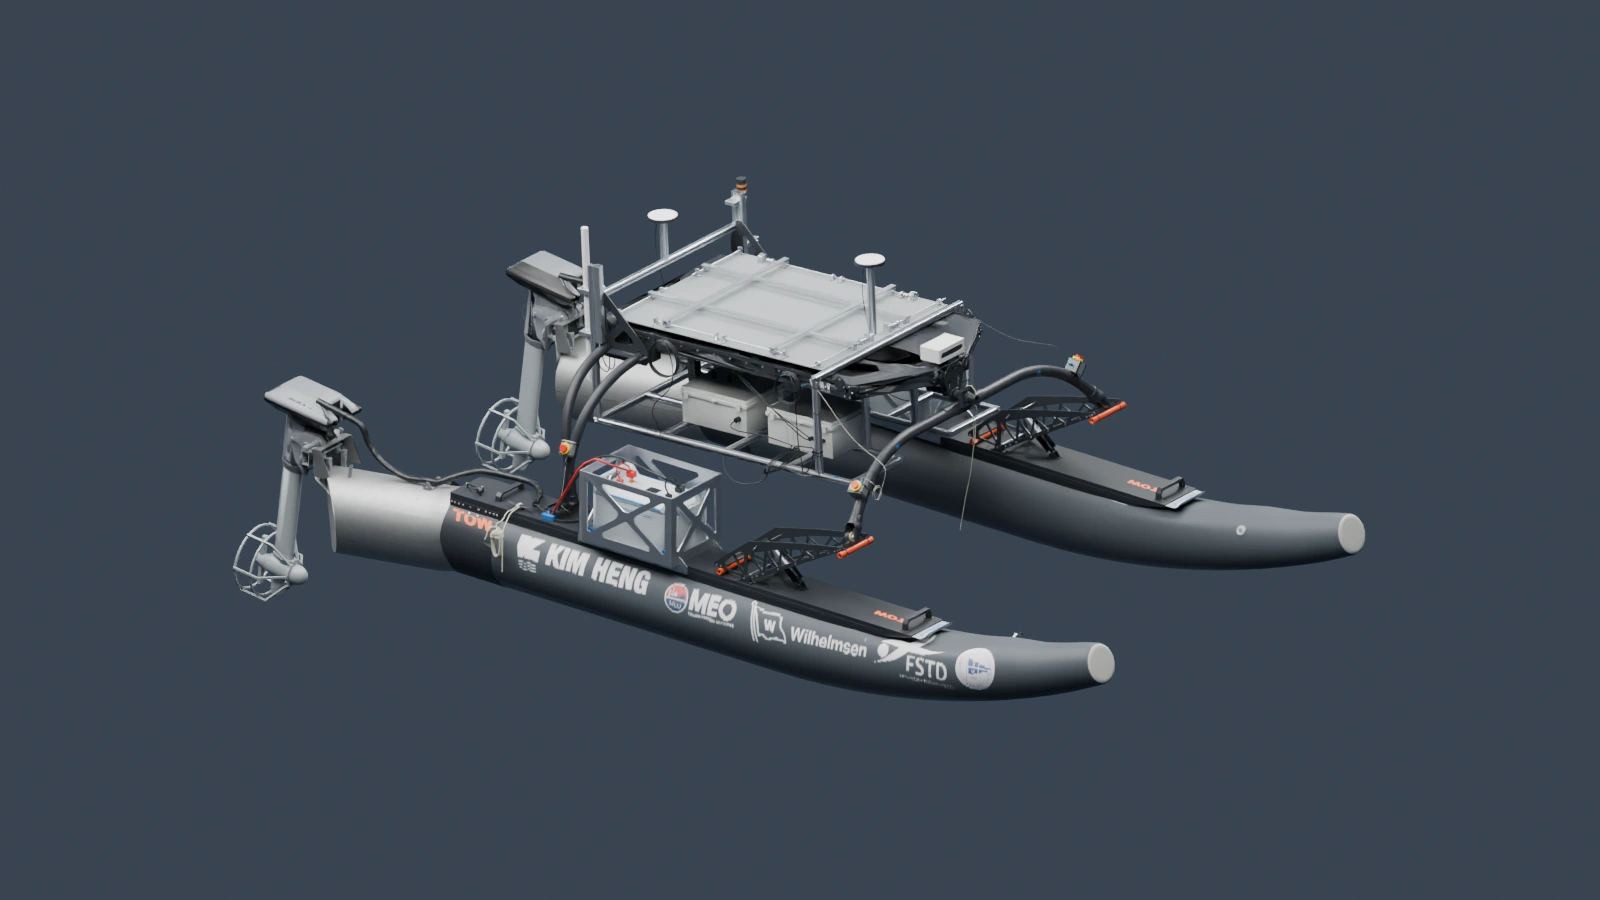
Rotatable view of the supplied USV 1.0 assembly in its November 2024 configuration, without the aircraft aboard.
Use your mouse or trackpad: drag to rotate, scroll to zoom.Drag to rotate. Pinch to zoom. With the model focused, use arrow keys to rotate, + or - to zoom, Home to reset, and Escape to leave the model.
Surge and yaw
2 × 60 kgf, rated
Nominal propulsion supply
Two independent E60 packs
Calculated, both packs
TDR-listed receiver spec
A ZED 2i stereo camera supplied object detections and depth. The Hemisphere GNSS receiver provided position and heading, while a hydrophone listened for acoustic signals beneath the surface.
Two Navy 3.0 Evo thrusters drove the hull and turned it through differential thrust. The CubeOrangePlus controlled speed and heading, with custom engine pods supporting the motors at the stern.
Each thruster had its own 48 V battery. Converters supplied lower-voltage electronics, and remotely controlled relays could isolate propulsion power. A shelf beneath the payload tray housed the protected electronics.
Ubiquiti radios linked the boat’s computer to shore. The ground station brought vehicle status into one display for troubleshooting, while a separate handheld controller allowed the operator to take manual control.
The onboard Jetson processed camera detections for waypoint planning. Detections had to persist across frames before use; the planner combined curved approaches and obstacle-aware routes with the low-level steering controller.
A four-rod docking mechanism was designed to secure the UAV during transit. A separate flywheel launcher used a drum reload mechanism to feed racquetballs for delivery from the surface vehicle.
A smaller surface build adds LiDAR, lateral thrust and water delivery for RobotX 2026.