Perception and positioning
The ZED 2i provided stereo images and depth for detection and mapping. An LD-06 LiDAR measured nearby obstacles, while the M9N GPS and flight-controller sensors supplied the aircraft’s navigation state.
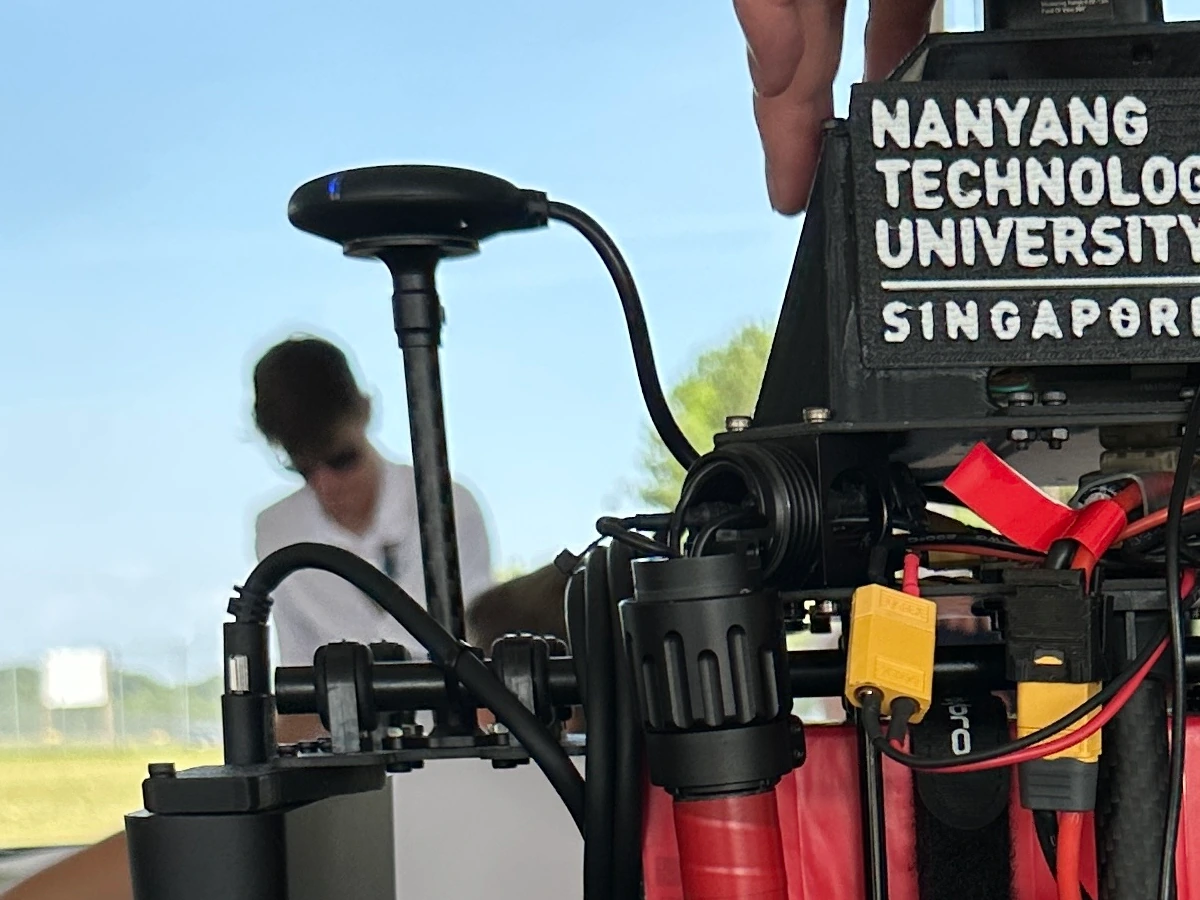
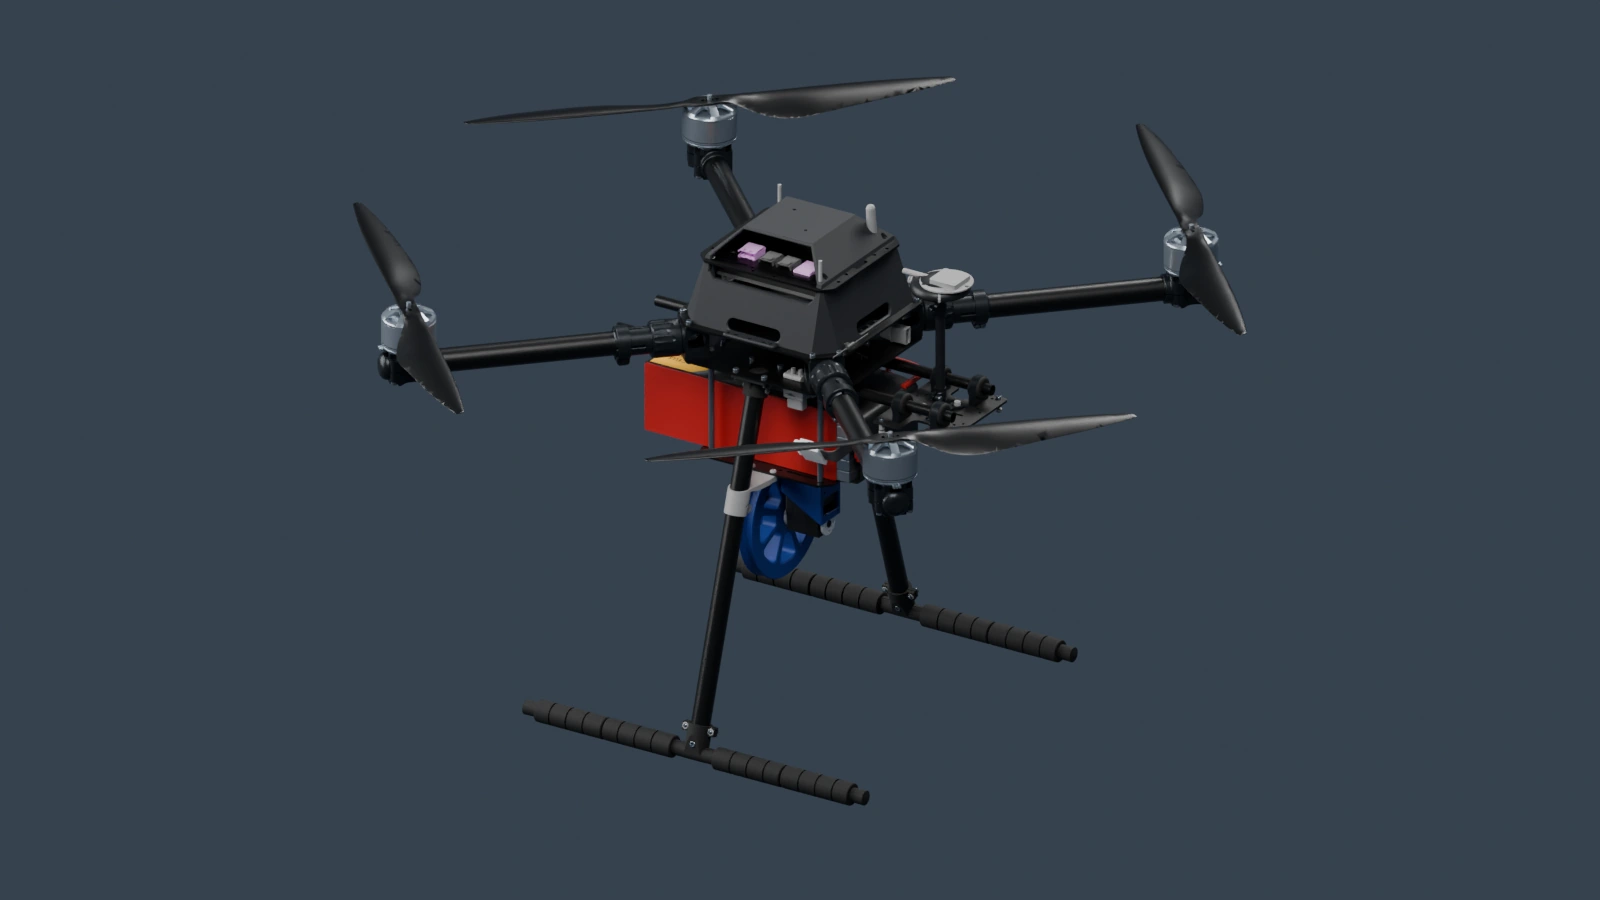
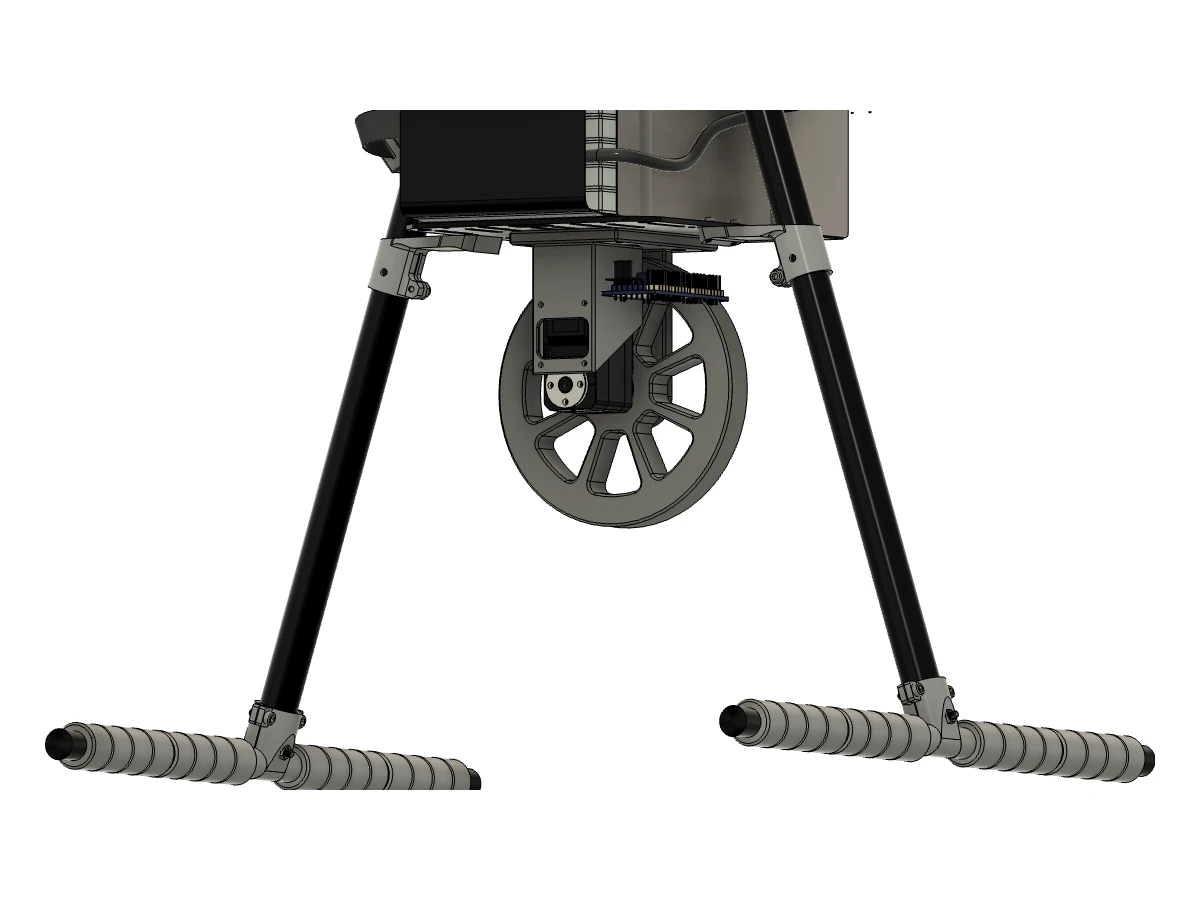
Rotatable view of the supplied UAV 2.0 STEP assembly, with materials guided by the team's photographs.
Use your mouse or trackpad: drag to rotate, scroll to zoom.Drag to rotate. Pinch to zoom. With the model focused, use arrow keys to rotate, + or - to zoom, Home to reset, and Escape to leave the model.
As built
Validated, after reserve
TDR-reported
Approximate
From 4 × 3.3 kgf
6S 22.2 V LiPo
Stereo vision, onboard GPU computing and a scanning LiDAR expanded the aircraft’s perception. A servo winch replaced the arm for controlled payload delivery, while a partially enclosed electronics package supported the new SUAS build.
The ZED 2i provided stereo images and depth for detection and mapping. An LD-06 LiDAR measured nearby obstacles, while the M9N GPS and flight-controller sensors supplied the aircraft’s navigation state.
The X650 V2 frame folded for transport. Four MN4014 motors drove 17-inch propellers, while PX4 combined position and attitude feedback in the Pixhawk 6X to make coordinated motor adjustments.
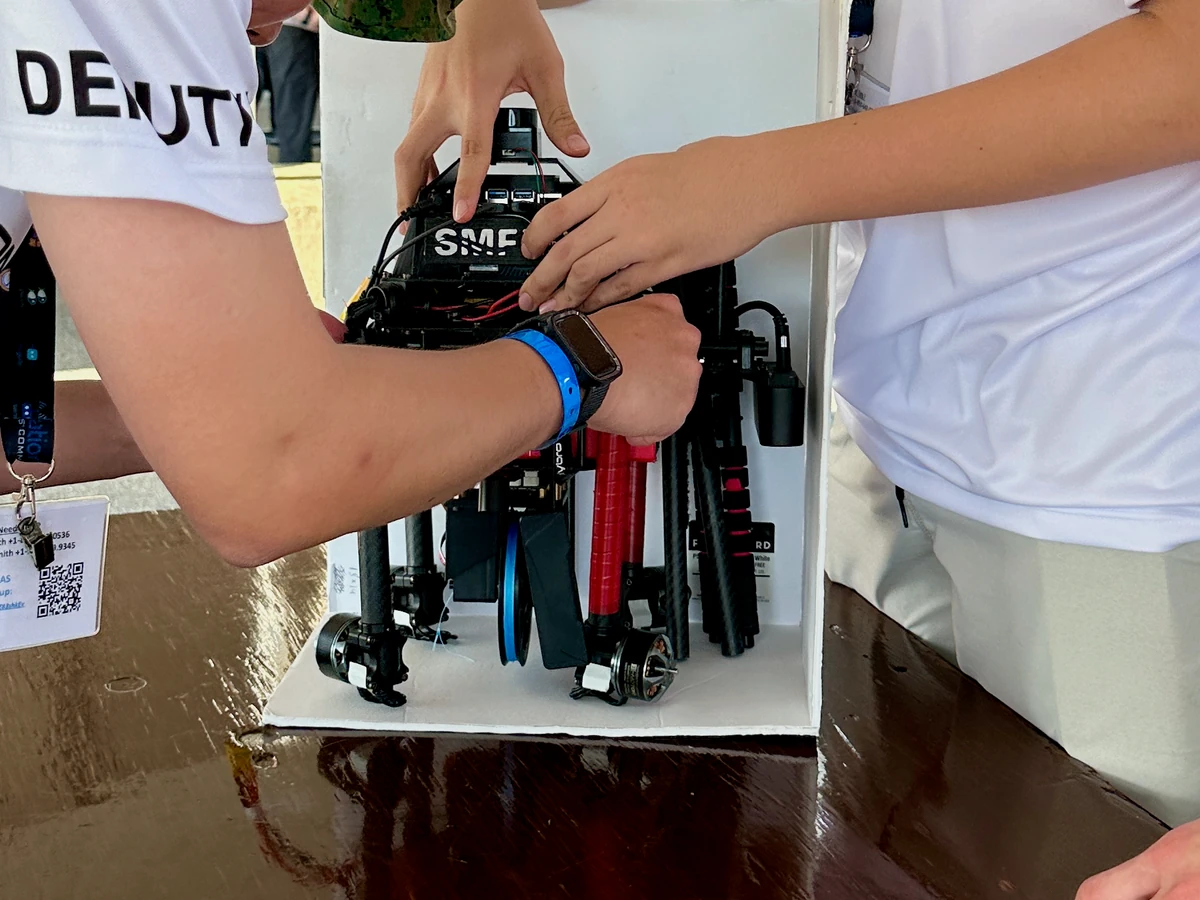
A servo-driven winch lowered the payload on a tether instead of releasing it from flight altitude. The onboard computer triggered the mechanism, with a constrained drum controlling how the tether paid out.
Four power branches served propulsion, flight control, the winch and the onboard computer. Separate 5 V and 12 V regulation matched each load, allowing the flight controller and payload electronics to share one battery.
SiK telemetry carried flight status and commands between the aircraft and ground station. An ELRS radio provided pilot control, while a 4G modem gave the team remote access to mission scripts and perception results.
The Jetson ran YOLOv8 detection and a customised mapping pipeline. MAVROS linked these mission functions to the flight controller; the navigation design also used stereo-visual positioning to compensate for GPS drift.
Waterproof motors, a fully enclosed electronics package and a new gripper prepare the next aircraft for RobotX 2026.