Skip to content
HomeVehiclesUUV 1.0
Subsea

UUV 1.0

Our first underwater vehicle, combining sonar, visual inspection and local navigation.

Generation 1 · In build · RobotX 2026
UUV 1.0 CAD with its front facing right, showing the sonar, upper enclosure and eight-thruster frame.

Rotatable view of the supplied UUV 1.0 STEP assembly with its integrated upper enclosure and underwater sensors.

Use your mouse or trackpad: drag to rotate, scroll to zoom.Drag to rotate. Pinch to zoom. With the model focused, use arrow keys to rotate, + or - to zoom, Home to reset, and Escape to leave the model.

Thrusters
8

T200 propulsion

Lights
4

Lumen illumination

Velocity sensing
A50

WaterLinked DVL

Imaging sonar
ECHO

Sonoptix

How it works.

Perception and inspection

Sonoptix ECHO measures range and bearing to underwater structures. The camera and four lights reveal colour and detail for close inspection.
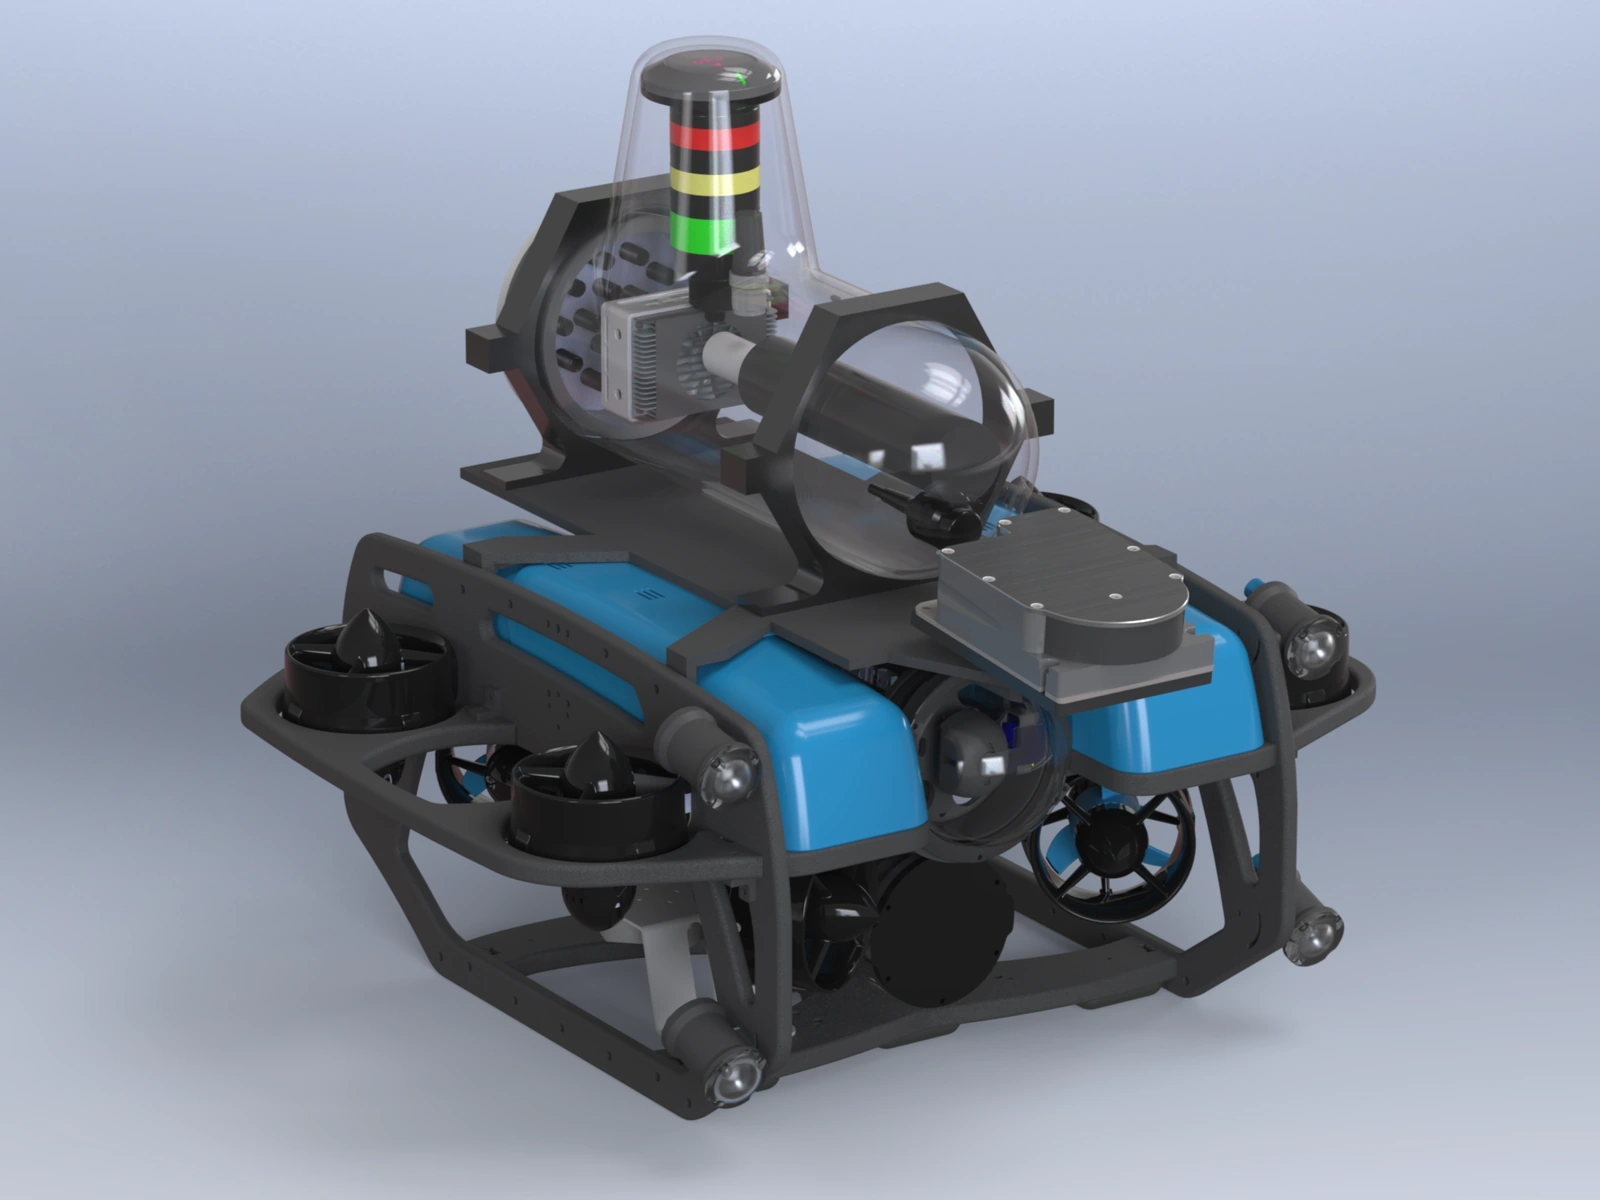
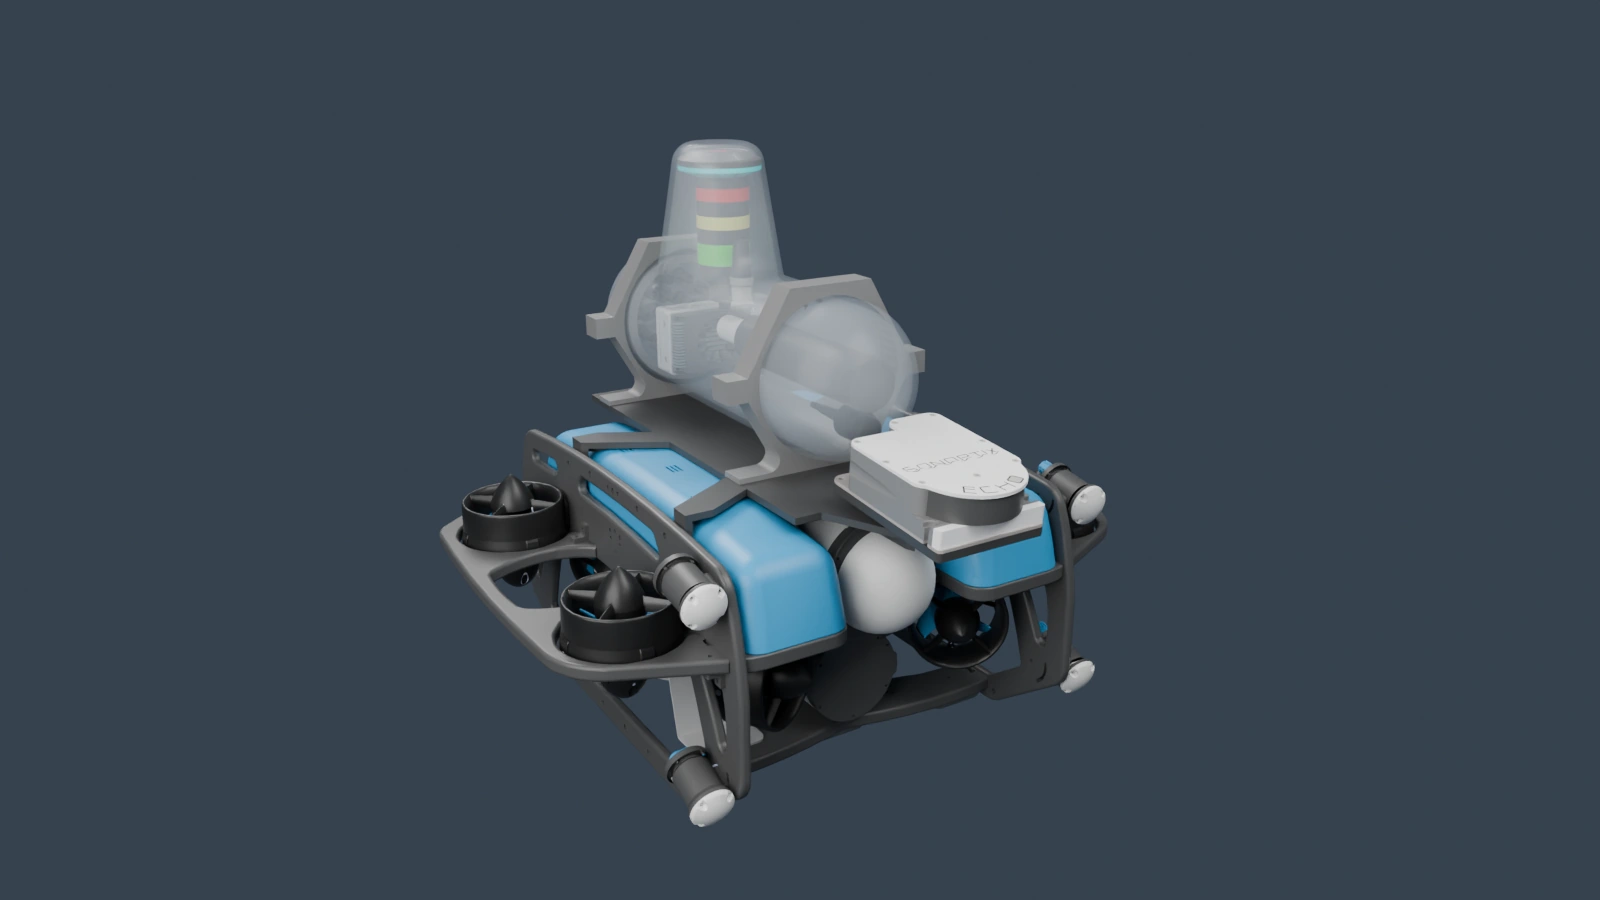
Right-side isometric view of UUV 1.0 showing its sonar, inspection camera and lights

Propulsion and control

Four horizontal and four vertical T200 thrusters control translation and attitude. ArduSub runs on the Raspberry Pi with Navigator I/O; the Jetson hosts inspection software.
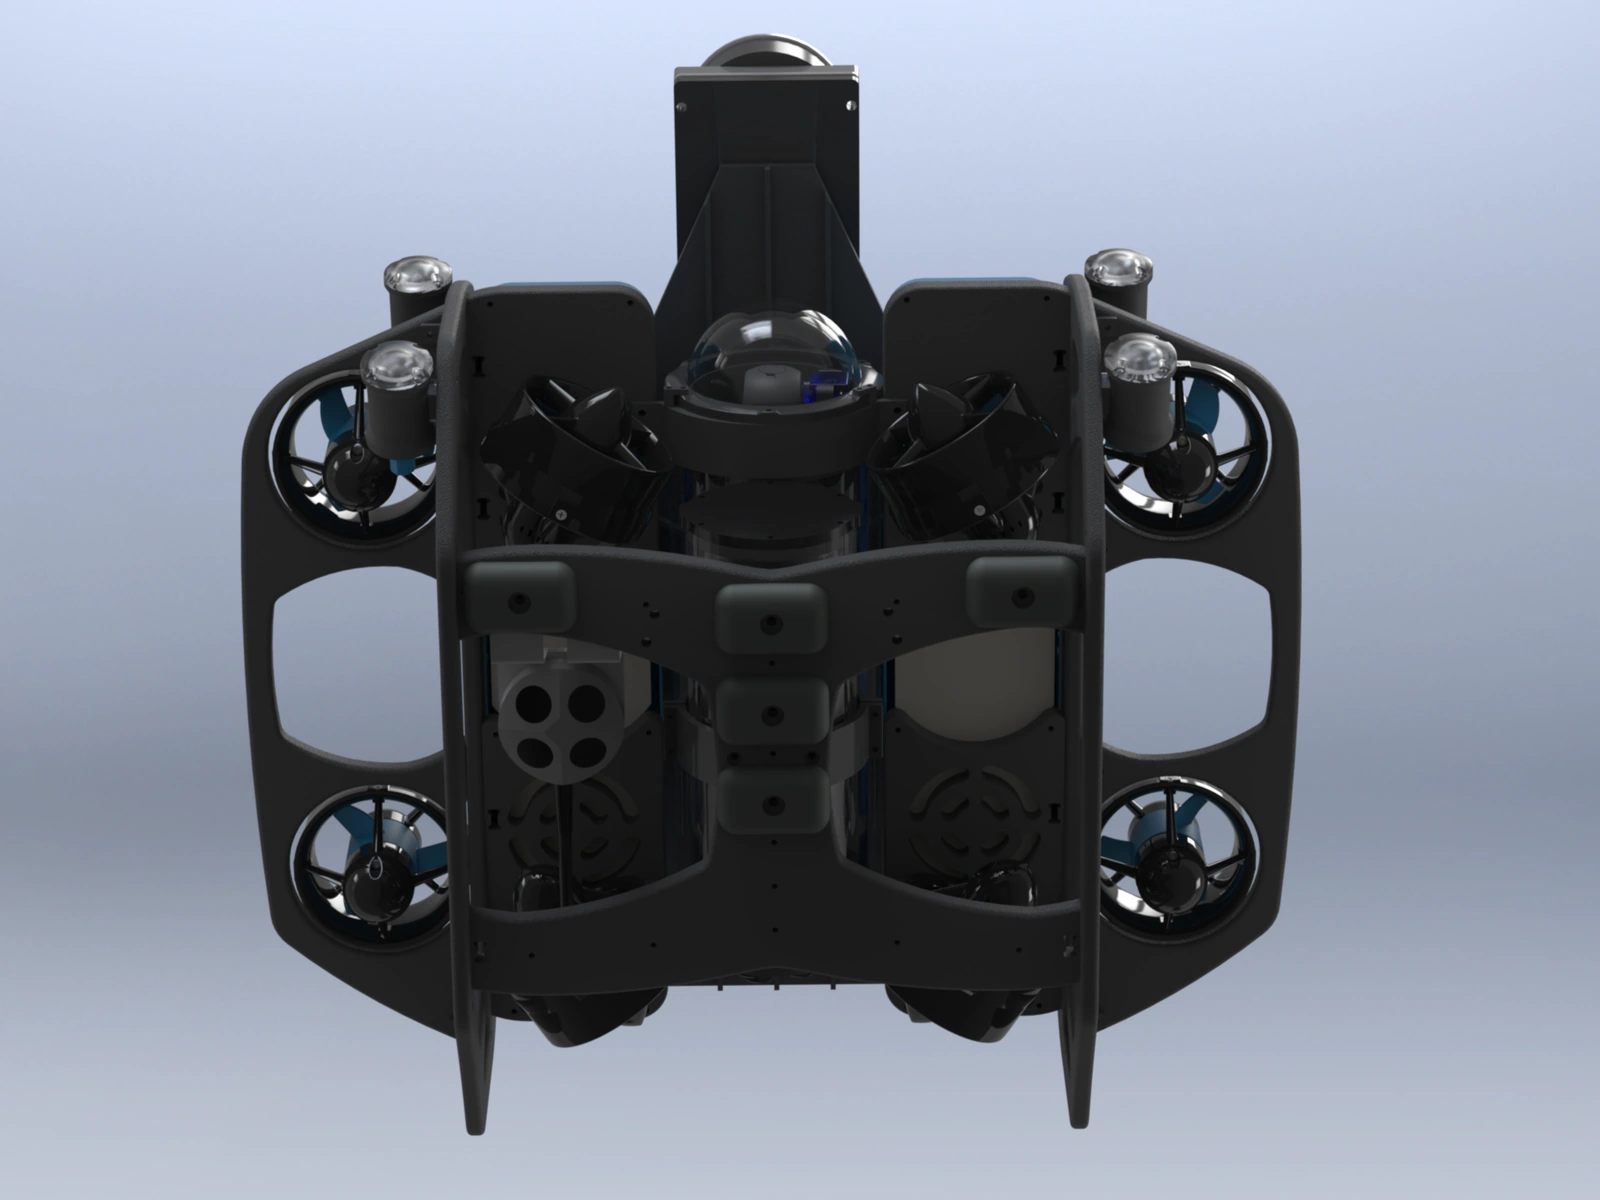
Underside of UUV 1.0 showing thrusters, lower frame and DVL

Power and integration

The battery supplies propulsion and electronics. Our upper enclosure houses the Jetson and communications equipment, with integration checks covering heat, cabling, buoyancy and trim.
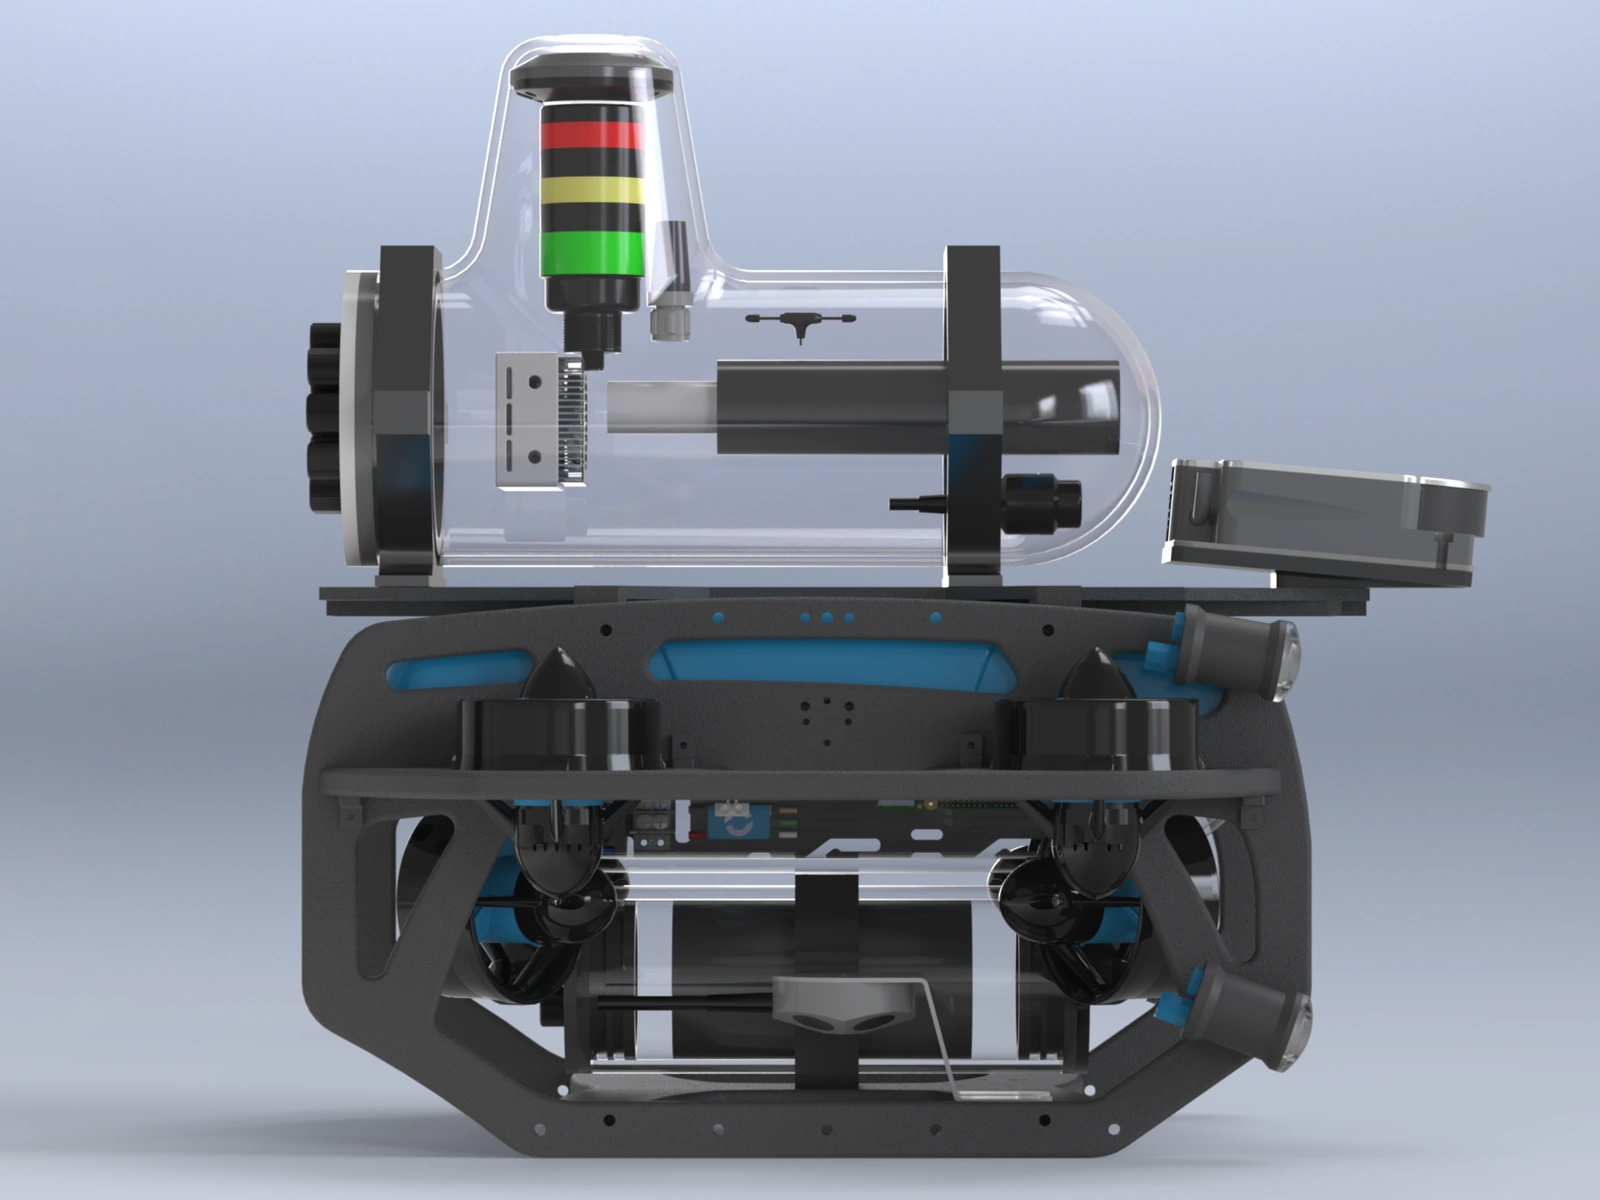
Side view of UUV 1.0 showing the transparent upper enclosure, communications equipment and sonar

Communications

An M16 acoustic modem carries compact messages through the USV underwater. At the surface, radio provides a shore connection and GNSS supplies a position reference.

Side view of UUV 1.0 showing the transparent upper enclosure, communications equipment and sonar

Navigation without underwater GPS

The A50 DVL measures bottom-relative velocity. Combined with depth and attitude sensing, it supports local navigation for pipeline inspection.
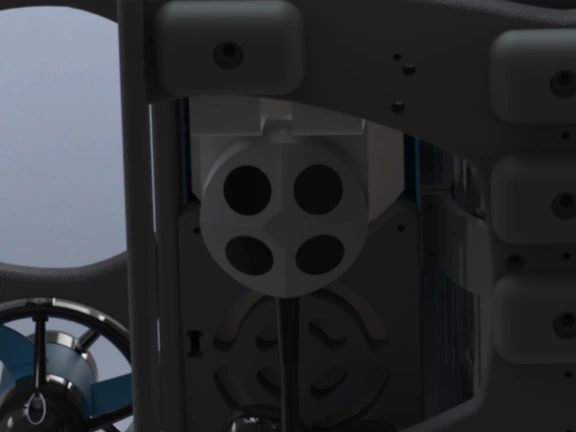
Close-up of the underside-mounted WaterLinked DVL and its four circular transducers

Inspection and intervention

The camera records pipeline condition lights before repair. A compliant magnetic probe is planned, with contact and indicator changes used to assess the outcome.

What’s on board.

Frame and enclosure

  • BlueROV2 Heavy frame
  • Custom upper electronics enclosure
  • Roof rack for the imaging sonar

Propulsion

  • Eight BlueRobotics T200 thrusters
  • Four vectored horizontal thrusters
  • Four vertical thrusters for depth and attitude

Power system

  • BlueRobotics onboard battery
  • Propulsion and electronics power supplies
  • Upper-enclosure power integration

Vehicle control

  • Raspberry Pi 4 with Navigator I/O
  • ArduSub vehicle control
  • BlueOS onboard services

Underwater navigation

  • WaterLinked A50 bottom-tracking DVL
  • Bar30 pressure and depth sensor
  • Attitude sensing through the vehicle controller

Onboard computer

  • NVIDIA Jetson Orin NX companion computer
  • Integrated in the custom upper enclosure

Imaging sonar

  • Sonoptix ECHO multibeam sonar
  • Range and bearing observations
  • Pipeline structure sensing

Vision and lighting

  • Low-light HD camera
  • Four BlueRobotics Lumen lights
  • Pipeline indicator and colour inspection

Acoustic communications

  • WaterLinked M16 Standard modem
  • Compact mission and status messages
  • Underwater link to the USV

Surface links and status

  • 5 GHz airMAX radio
  • Holybro H-RTK F9P surface GNSS
  • Status light tower

Mission interfaces

  • Compliant magnetic probe (planned)
  • Mounting and contact design for pipeline repair

Software

  • MAVROS companion link to ArduSub
  • Single DVL input path through BlueOS
  • Ordered pipeline-survey logic in development

One fleet. Three domains.